|
Mingyu Park Hi! I am Mingyu Park. I am a post-master's researcher at ETRI in South Korea. Previously, I earned M.S. from KAIST, where I was advised by Prof. Donghwan Lee. My research goal is to build robot learning foundations that generalize across diverse environments and tasks, enabling robots to replace everyday chores with true autonomy. To achieve this goal, I investigate algorithms for reinforcement learning, imitation learning, and self-supervised representation learning.
|
|


Recent News 📣 |
|
(Sep., 2026) VIGOR is accepted by NeurIPS 2026! (Sep., 2025) PSQN is accepted by NeurIPS 2025! (Sep., 2025) I started working as a Post-master's researcher at ETRI! (Feb., 2025) I graduated the Master's degree with the robotics program at KAIST! |
Publications |
|
VIGOR: Zero-Shot Visual Generalization via Latent-Space Consistency in Model-Based Reinforcement Learning
Mingyu Park*, Samyeul Noh*, Hyun Myung†, Donghwan Lee† NeurIPS, 2026 (* equal contribution, † equal advising) paper / site Model-based RL (MBRL) demonstrates strong sample efficiency by leveraging the synthetic trajectories from the learned transition model. However, current MBRL lacks visual generalization when unseen visual input is given to the model, limiting further deployment. VIGOR achieves zero-shot generalization to unseen visual distractions while preserving high sample efficiency, building upon TD-MPC2 and DreamerV3, which are the most popular MBRL baselines. |
|
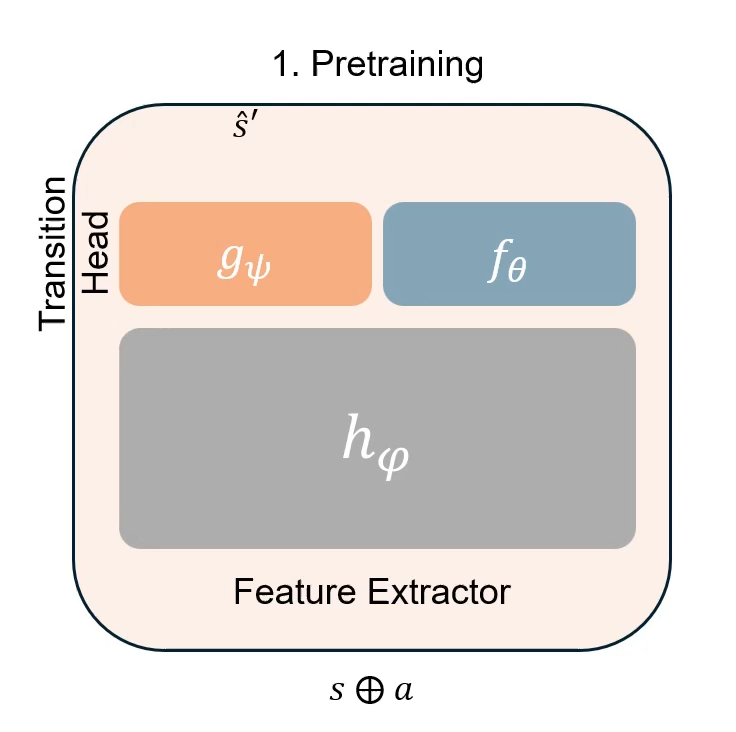
Pretraining a Shared Q-Network for Data-Efficient Offline Reinforcement Learning
Jongchan Park*, Mingyu Park*, Donghwan Lee† NeurIPS, 2025 (* equal contribution) paper / site Pretraining a shared $Q$-network with a supervised regression task significantly improves the performance of existing offline RL methods, demonstrating a strong data efficiency only with 10% of a dataset on the D4RL benchmark. |
|
Computational Cost Reduction Method for HQP-based Hierarchical Controller for Articulated Robot
Mingyu Park, Dongwhan Kim, Yongwhan Oh, Yisoo Lee† KROS, 2022 paper / site Reduced hierarchical quadratic programming (rHQP) is an optimal real-time controller for articulated redundant dual-arm manipulators. rHQP solves about x2.44 faster than the conventional HQP on average. |
Education |
 |
KAIST(Korea Advanced Institute of Science and Technology) (Mar. 2023 - Feb. 2025) M.S. in Robotics Program |
 |
Kwangwoon University (Mar. 2017 - Feb. 2023) B.S. in Robotics Engineering |
Work experiences |
 |
ETRI(Electronics and Telecommunications Research Institute) Post-master's researcher at Digital Convergence Research Laboratory |
 |
SNU (Seoul National University) (Jan. 2022 - Oct. 2022) Undergraduate Research intern advised by Prof. Jaeheung Park. Check details at project page! |
 |
KIST(Korea Institute of Science and Technology) (Jun. 2021 - Dec. 2021) Undergraduate Research Assistant advised by Dr. Yisoo Lee. |
Academic Services |
|
Leadership & Training |
 |
University of Southern Denmark
International Elite Summer School in Robotics & Entrepreneurship (Aug. 2023). Participated in the summer school to have a better academic knowledge of robotics, regarding advanced techniques for designing robotic systems and entrepreneurship in robotic startup companies (e.g. Universal Robots) in Denmark. Enlarged an international network with peer students engaging in robotic innovation from diverse countries |
 |
Kwangwoon university
Coordinator (2022), Member (2020-2021), BARAM (Robotics Academic Group) Served as a club director for members by organizing an annual exhibition of hand-crafted robots. Organized academic seminars on robotics, mentored freshmen, and participated in semester-long robot projects Check details at project page! |
|
Template is borrowed from here. |